Ultrasound Robotics Workflows#
Workflows for robot-assisted ultrasound probe positioning and scanning.
Workflows#
| Workflow | Demonstration | Supported modes (guide) |
|---|---|---|
ultrasound_liver_scan |
Move an ultrasound probe across an abdominal phantom. | policy, rule-based, teleop, replay, idle |
ultrasound_probe_reach |
Align an ultrasound probe with a randomized target. | policy, idle |
Demonstrations#
Open the preview to view the animated demonstration.
ultrasound_liver_scan |
|---|
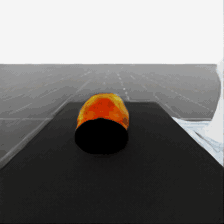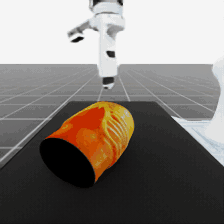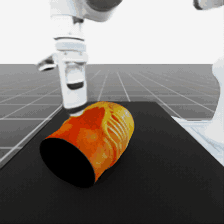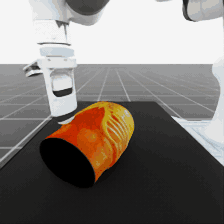 |
Note: Complete the project setup before you begin.
Run with an AI Agent#
Paste this prompt into Claude Code, Codex, or the repository's Local Agent:
Evaluate ultrasound_liver_scan for 1 episode.
The agent runs the workflow, verifies the episode result, and inspects its recorded artifacts.
Run from the Command Line#
# Sweep the liver phantom with the rule-based controller.
./run.sh ultrasound_liver_scan --rule-based

# Control the liver-scan probe with the keyboard.
./run.sh ultrasound_liver_scan --teleop
RL Training#
ultrasound_probe_reach supports the maintained RSL-RL PPO training profile. A trained checkpoint is not included; train and export one before using policy mode.
Train with an AI Agent#
Train ultrasound_probe_reach with RL.
Evaluate 20 episodes and validate the exported policy.
The agent dry-runs, trains, evaluates, exports, and validates the policy.
Train from the Command Line#
Run the complete training lifecycle:
# Inspect the maintained RSL-RL PPO profile.
./train.sh rl show ultrasound_probe_reach

# Dry-run the training configuration.
./train.sh rl ultrasound_probe_reach \
  --num-envs 128 \
  --epochs 400 \
  --dry-run

# Train the policy from scratch.
./train.sh rl ultrasound_probe_reach \
  --num-envs 128 \
  --epochs 400

# Copy the timestamped run directory printed by the training command.
TRAIN_RUN="$PWD/runs/ultrasound_probe_reach/YYYYMMDD_HHMMSS"

# Evaluate the trained checkpoint.
./train.sh rl ultrasound_probe_reach \
  --eval \
  --checkpoint "$TRAIN_RUN/model_final.pt" \
  --episodes 20

# Export the verified policy to TorchScript.
./train.sh rl export ultrasound_probe_reach \
  --checkpoint "$TRAIN_RUN/model_final.pt" \
  --output-dir "$TRAIN_RUN/exported"

# Validate the exported policy through the Workflow.
./run.sh ultrasound_probe_reach --policy \
  --checkpoint "$TRAIN_RUN/exported/policy.pt" \
  --episodes 20
RSL-RL training and evaluation are a separate lifecycle, not workflow run modes.