Laparoscopic Robotics Workflows#
These workflows use dVRK PSM or STAR robots for laparoscopic manipulation and instrument positioning.
Workflows#
| Workflow | Demonstration | Supported modes (guide) |
|---|---|---|
surgical_reach_psm |
One dVRK PSM reaches a target. | rule-based, replay, idle |
surgical_reach_dual_psm |
Two dVRK PSM arms reach separate targets in parallel. | rule-based, replay, idle |
surgical_reach_star |
A STAR arm reaches a target. | rule-based, replay, idle |
surgical_lift_block |
A dVRK PSM grasps and lifts a peg-transfer block. | rule-based, replay, idle |
surgical_lift_needle |
A dVRK PSM grasps and lifts a suture needle. | rule-based, replay, idle |
surgical_lift_needle_organs |
A dVRK PSM lifts a suture needle from an organ bed. | rule-based, replay, idle |
Demonstrations#
Open the preview to view the animated demonstration.
| Rule-based workflow evaluations |
|---|
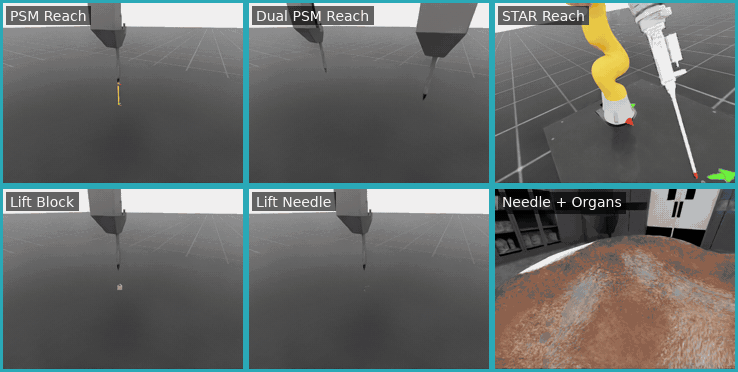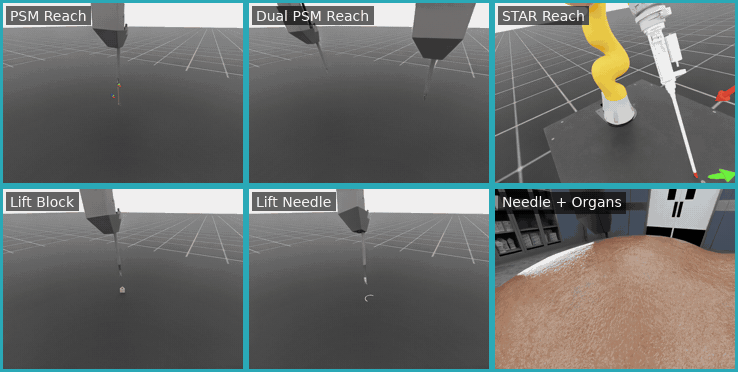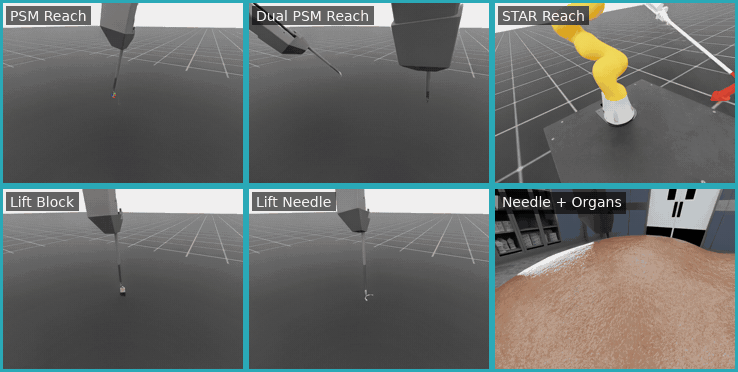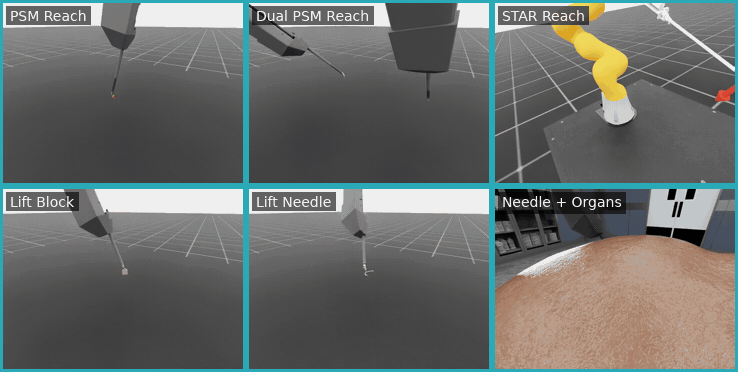 |
Note: Complete the project setup before you begin.
Run with an AI Agent#
Paste any prompt into Claude Code, Codex, or the repository's Local Agent:
Run surgical_reach_psm in rule-based mode for 1 episode.

Run surgical_reach_dual_psm in rule-based mode for 1 episode.

Run surgical_reach_star in rule-based mode for 1 episode.

Run surgical_lift_block in rule-based mode for 1 episode.

Run surgical_lift_needle in rule-based mode for 1 episode.

Run surgical_lift_needle_organs in rule-based mode for 1 episode.
The agent runs the selected workflow, verifies the episode result, and inspects its recorded artifacts.
Run from the Command Line#
# Reach a target with one dVRK PSM.
./run.sh surgical_reach_psm --rule-based

# Reach two targets with two dVRK PSM arms.
./run.sh surgical_reach_dual_psm --rule-based

# Reach a target with a STAR arm.
./run.sh surgical_reach_star --rule-based

# Lift a peg-transfer block.
./run.sh surgical_lift_block --rule-based

# Lift a suture needle.
./run.sh surgical_lift_needle --rule-based

# Lift a suture needle from an organ bed.
./run.sh surgical_lift_needle_organs --rule-based
📚 Citations#
This workflow originated from the ORBIT-Surgical framework. If you use it in academic publications, please cite:
@inproceedings{ORBIT-Surgical,
  author={Yu, Qinxi and Moghani, Masoud and Dharmarajan, Karthik and Schorp, Vincent and Panitch, William Chung-Ho and Liu, Jingzhou and Hari, Kush and Huang, Huang and Mittal, Mayank and Goldberg, Ken and Garg, Animesh},
  booktitle={2024 IEEE International Conference on Robotics and Automation (ICRA)},
  title={ORBIT-Surgical: An Open-Simulation Framework for Learning Surgical Augmented Dexterity},
  year={2024},
  pages={15509-15516},
  doi={10.1109/ICRA57147.2024.10611637}
}

@inproceedings{SuFIA-BC,
  author={Moghani, Masoud and Nelson, Nigel and Ghanem, Mohamed and Diaz-Pinto, Andres and Hari, Kush and Azizian, Mahdi and Goldberg, Ken and Huver, Sean and Garg, Animesh},
  booktitle={2025 IEEE International Conference on Robotics and Automation (ICRA)},
  title={SuFIA-BC: Generating High Quality Demonstration Data for Visuomotor Policy Learning in Surgical Subtasks},
  year={2025},
  pages={4534--4541},
  publisher={IEEE},
  doi={10.1109/ICRA55743.2025.11127797}
}